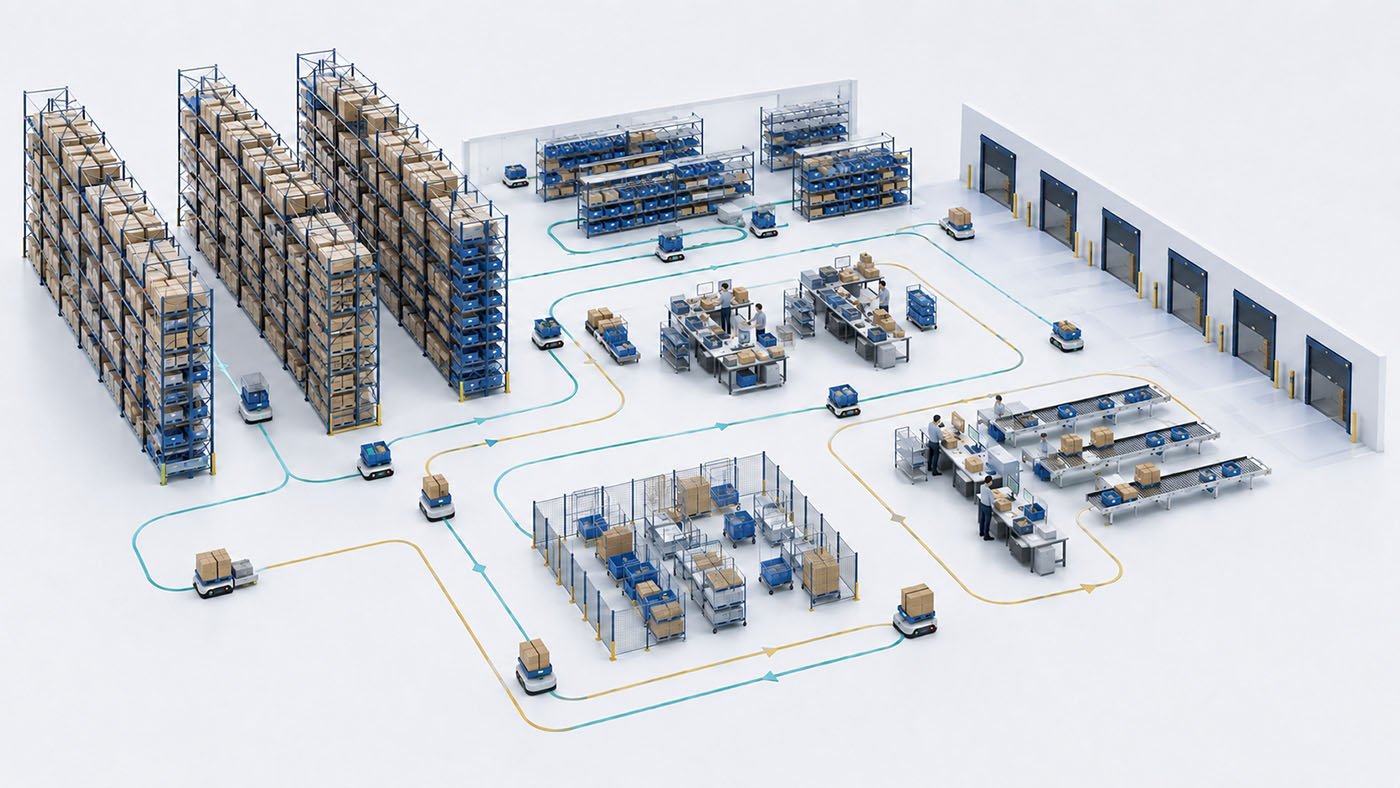
Warehouse leaders should evaluate the operating problem before selecting an autonomous mobile robot. AMRs can reduce travel, stabilize material movement, and add flexible capacity. They can also shift bottlenecks downstream or automate a weak process. Start with the work, data, and constraints—not the robot.
Direct answer: DIRECT ANSWER An autonomous mobile robot, or AMR, moves materials without following a fixed physical path. It uses sensors, mapping, and software to navigate within a defined operating area. AMRs make sense when repeatable movement consumes substantial labor or limits throughput. They do not fix poor slotting, unreliable inventory, weak processes, or inadequate systems.
What is an autonomous mobile robot?
An AMR is a mobile machine that navigates through a warehouse and completes assigned transport tasks. Its sensors detect features, people, equipment, and obstacles within the operating environment. Navigation software uses that information to select or adjust a route. A fleet manager then assigns work across multiple robots.
AMRs carry different payloads for different applications. Some move shelves, carts, totes, cartons, or pallets. Others guide associates through picking or connect work areas. Define the load and workflow before comparing robot specifications.
An AMR does not operate independently of the business process. Warehouse software must create, prioritize, and confirm the work in many applications. People must handle exceptions, maintain equipment, and manage the operating area. Treat the robot as one component within a larger execution system.
How do AMRs differ from AGVs, conveyors, and conventional equipment?
AMRs differ primarily in how they navigate and how easily the operation can change. Traditional automated guided vehicles usually follow defined routes supported by wires, tape, markers, or other guidance. AMRs calculate routes within an approved map and respond to changing conditions. That flexibility can reduce infrastructure work, but it does not eliminate engineering.
Conveyors create fixed, high-volume paths between known points. AMRs create flexible transport capacity across changing routes and destinations. Forklifts and carts provide human-controlled flexibility but require labor for every trip. Compare the complete workflow rather than treating these technologies as interchangeable.
Companies evaluating automated warehouse robots should compare AMRs with AGVs, conveyors, forklifts, and other technologies. A conveyor may serve a stable trunk route while AMRs handle variable branches. Lift trucks may remain necessary for unusual loads or recovery. A warehouse layout and design review should model the total material flow before selecting equipment.
What warehouse applications fit AMRs best?
AMRs fit repeatable movement with clear origins, destinations, loads, and service expectations. The best applications usually contain substantial non-value-added travel. They also have enough volume to keep the equipment productively utilized. Measure trips and wait time before designing the solution.
Collaborative order picking
Collaborative picking AMRs reduce the distance associates push carts or transport completed work. The robot may travel between zones while associates remain within smaller pick areas. Software must coordinate orders, routes, associates, and destination capacity. Evaluate the entire pick-to-pack cycle, not only picks per hour.
Goods-to-person picking
Goods-to-person AMRs bring shelves, racks, or containers to staffed workstations. This design can reduce walking and improve workstation consistency. It also creates dependencies on storage density, replenishment, workstation balance, and presentation logic. Confirm that item characteristics and order profiles support the concept.
Point-to-point material transport
Transport AMRs move totes, cartons, carts, or pallets between defined process areas. Common routes connect receiving, putaway staging, replenishment, picking, packing, and shipping. This application works best when employees spend meaningful time moving material instead of processing it. Quantify trips by hour and by shift.
Replenishment and line feeding
AMRs can deliver inventory to pick areas or production lines on a scheduled or demand-driven basis. The application requires dependable task signals and destination availability. Late replenishment can stop picking even when the robot fleet performs correctly. Design the information flow with the physical flow.
Sortation, consolidation, and returns support
AMRs can route completed containers to consolidation, packing, inspection, or return-processing stations. This flexibility helps when destinations change by order, customer, or disposition. The downstream area must accept work at the rate robots deliver it. Test congestion and accumulation under peak conditions.
What problems do AMRs solve well?
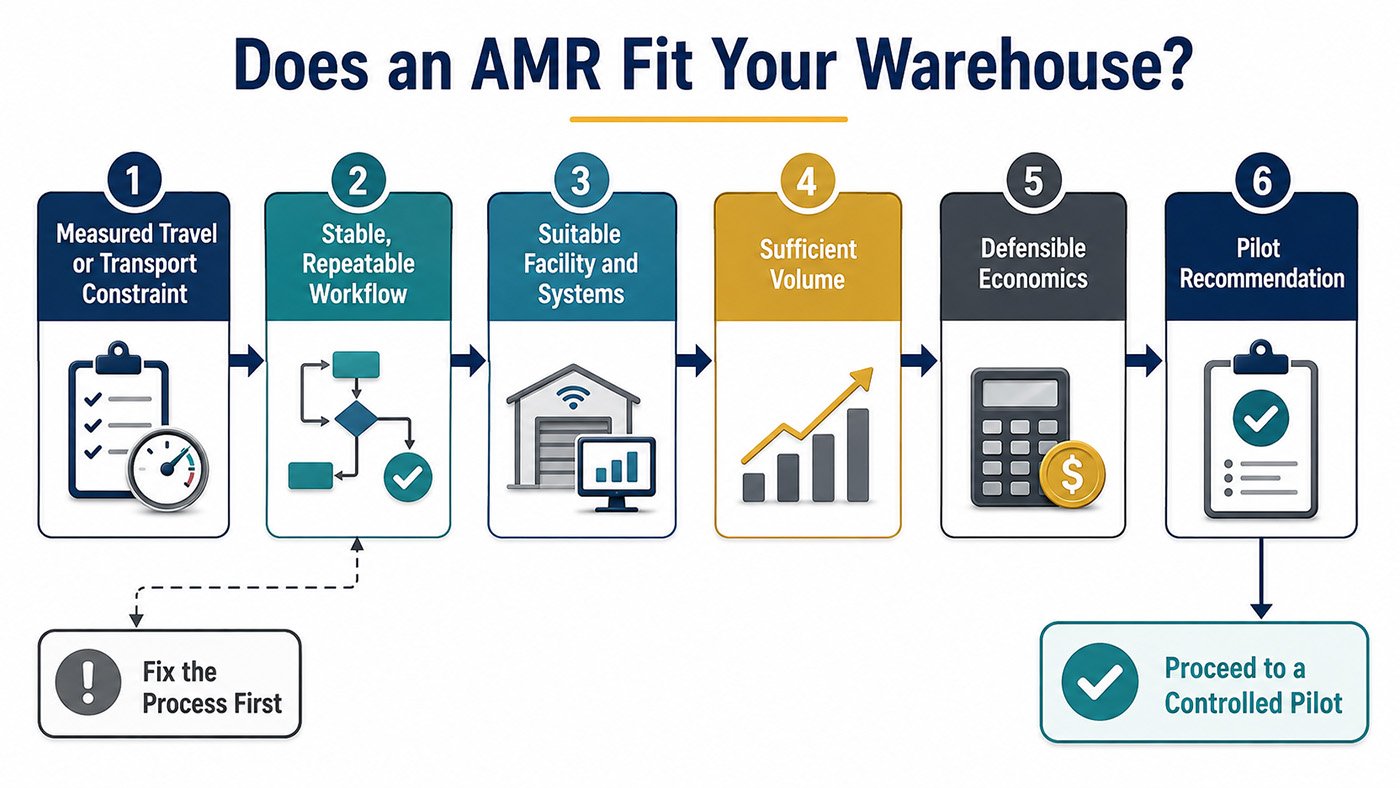
AMRs solve movement problems better than process problems. They can reduce walking, manual cart handling, and waiting for transport. They can also create more predictable handoffs between work areas. Select an application only after its baseline constraint is measured.
Strong candidates often share four characteristics:
- Employees spend material time walking or moving loads.
- The work repeats often enough to support high robot utilization.
- Origins, destinations, and task rules can be defined reliably.
- The receiving process can absorb the delivered work without creating congestion.
AMRs can also provide flexible capacity during growth. Companies may add robots without extending a fixed conveyor path. That scalability has limits because chargers, intersections, workstations, and software can still become constrained. Model the future fleet, not only the pilot fleet.
When is an AMR probably the wrong solution?
An AMR is probably wrong when the root problem lies elsewhere. Poor slotting, excess inventory, inaccurate locations, and weak replenishment create unnecessary movement. Automating that movement can make an inefficient process move faster. Compare AMRs with other material handling solutions after correcting avoidable work.
Low or highly irregular task volume can also weaken the business case. Robots create value while completing useful work, not while waiting for assignments. Extreme peaks may require an uneconomic fleet that sits idle for most of the year. Compare ownership, leasing, and temporary operating alternatives.
The physical environment can disqualify an application. Inadequate aisle width, damaged floors, steep grades, clutter, unstable loads, and uncontrolled pedestrian traffic create risk. Cold, wet, dusty, or hazardous areas may require specialized equipment. Validate the complete operating environment before requesting proposals.
Complex exceptions can overwhelm an otherwise simple design. Damaged cartons, missing inventory, blocked destinations, and unusual loads require defined recovery procedures. If exceptions occur frequently, the system may need extensive human support. Measure exception frequency before estimating labor savings.
Have Questions? Not sure whether AMRs fit your operation? FCBCO can independently evaluate the application, requirements, economics, and alternatives before you approach vendors. Discuss your warehouse automation decision with FCBCO.
What operating data should executives review first?
Executives should require a fact base before approving an AMR concept. Averages alone hide the variation that determines fleet size and workstation capacity. Use at least 12 months of transaction history when seasonality affects the operation. Analyze normal, peak, and stress conditions separately.
The baseline should include:
- Orders, lines, units, and cartons by day and hour.
- Trips by origin, destination, load type, and shift.
- Travel distance, travel time, queue time, and blocked time.
- SKU velocity, dimensions, weight, and handling restrictions.
- Pick methods, replenishment demand, and workstation capacity.
- Labor hours, overtime, turnover, training, and supervision.
- Errors, exceptions, damage, downtime, and missed cutoffs.
- Forecast growth, assortment changes, and peak requirements.
- Robots, payload modules, carts, racks, and transfer equipment.
- Fleet-management, orchestration, WES, or subscription fees.
- WMS, ERP, conveyor, door, elevator, or workstation integration.
- Chargers, batteries, electrical work, and charging space.
- Floor repair, markings, guarding, signage, and facility changes.
- Engineering, simulation, project management, testing, and commissioning.
- Training, spare parts, preventive maintenance, and technical support.
- Travel, taxes, freight, cybersecurity review, and contingency.
- Internal labor for design, testing, training, and change management.
- Temporary productivity loss during startup and stabilization.
- Completed missions and units moved per hour.
- Associate travel and direct labor hours.
- Queue time, blocked time, and mission cycle time.
- Robot availability, charging time, interventions, and downtime.
- Pick or transfer accuracy and inventory synchronization.
- Safety events, near misses, congestion, and employee feedback.
- Downstream throughput, cutoff performance, and exception volume.
- The exact workflow, load, routes, and operating conditions assumed.
- Required robot count for average, peak, and degraded conditions.
- WMS, WES, fleet, and equipment integration responsibilities.
- Throughput, mission time, uptime, and intervention assumptions.
- Safety responsibilities, risk-assessment scope, and documentation.
- Site preparation, network, charging, and facility requirements.
- Testing, acceptance, training, support, and escalation procedures.
- Warranty, software licensing, cybersecurity, and upgrade policies.
- Expansion pricing, interoperability, data access, and exit rights.
- References with comparable workflows, loads, and operating scale.
Map each expected benefit to a measured baseline. “Reduce travel” requires current travel time or distance. “Increase throughput” requires output by hour and constraint. “Reduce labor” requires a credible task-level labor model. Reject benefits that cannot be measured before implementation.
What facility requirements can determine AMR feasibility?
Facility conditions can determine feasibility before software or price matters. Robots require safe travel lanes, turning space, transfer clearances, and appropriate floor conditions. Doors, elevators, ramps, fire exits, docks, and mezzanines may create special requirements. A comprehensive warehouse assessment should verify the layout, travel paths, floor conditions, traffic, utilities, and operating constraints.
Traffic design matters as the fleet grows. A route that supports three robots may fail with fifteen. Intersections, narrow aisles, staging areas, chargers, and manual equipment create shared constraints. Simulate or stress-test the expected peak fleet before final approval.
Charging also affects capacity. Battery type, duty cycle, charge strategy, charger location, and maintenance rules determine availability. Opportunity charging may reduce battery swaps but can increase charger traffic. Include charging behavior in the fleet model.
Wireless coverage must support the chosen architecture. Some navigation functions may remain onboard, while task updates and fleet coordination depend on connectivity. Measure coverage, roaming behavior, latency, and interference in the actual operating area. Test failure and recovery instead of assuming perfect Wi-Fi.
How should AMRs integrate with WMS, WES, and fleet software?
Effective warehouse management system integration should assign clear authority to every connected system. The WMS usually owns inventory, locations, orders, and warehouse transactions. A WES may release work and coordinate labor or automation. Fleet software assigns missions, routes robots, manages traffic, and monitors equipment.
Define the handoffs before development begins. Document which system creates a task, changes its priority, confirms pickup, confirms delivery, and closes the transaction. Include cancellations, duplicate messages, lost connectivity, and rejected destinations. Test every exception that could leave physical inventory out of sync.
Avoid treating a successful interface call as a successful business process. A message can transmit correctly while the carton reaches the wrong operational state. End-to-end testing must verify data, physical movement, workstation behavior, and inventory updates. Use production-like volumes during testing.
Multi-vendor fleets require additional planning. Interoperability initiatives can share robot status and location data, but they do not automatically provide one universal task manager. Vendors may also use different maps, chargers, interfaces, and safety controls. Define the desired interoperability before selecting equipment.
How should a company build an AMR business case?
A defensible business case compares the future operating process with the current process. Robot counts and vendor paybacks should come after the operating model. Calculate savings at the task level. Then test the result against realistic adoption, uptime, and growth assumptions.
Use this basic structure:
Annual net benefit = labor savings + avoided costs + measurable service benefits − recurring operating costs
Simple payback = total implementation investment ÷ annual net benefit
The formula is simple, but the assumptions require discipline. Labor savings should reflect positions or hours that the operation can actually avoid or redeploy. Throughput benefits should reflect a constraint that creates revenue, overtime, or service impact. Do not assign financial value to theoretical capacity without a business use.
Build at least three cases. The conservative case should use lower productivity and higher implementation costs. The expected case should use validated pilot performance. The upside case should never substitute for the approval case.
What costs exist beyond the robots?
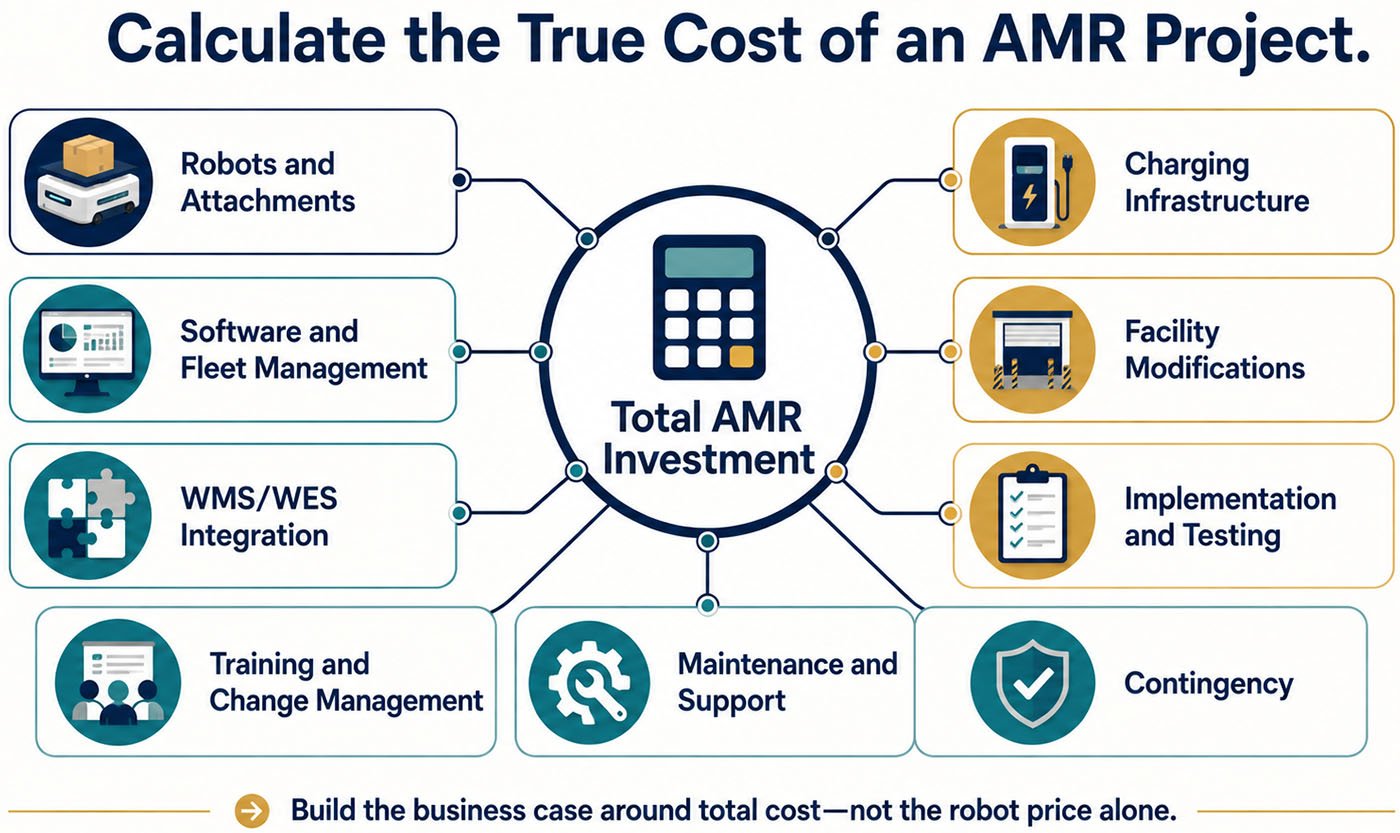
The robot price rarely represents the full investment. Integration, software, charging, network work, site preparation, and project management can materially change the economics. Training and operational support also continue after go-live. Build a total-cost model before comparing proposals.
Include these cost categories:
- Robots, payload modules, carts, racks, and transfer equipment.
- Fleet-management, orchestration, WES, or subscription fees.
- WMS, ERP, conveyor, door, elevator, or workstation integration.
- Chargers, batteries, electrical work, and charging space.
- Floor repair, markings, guarding, signage, and facility changes.
- Engineering, simulation, project management, testing, and commissioning.
- Training, spare parts, preventive maintenance, and technical support.
- Travel, taxes, freight, cybersecurity review, and contingency.
- Internal labor for design, testing, training, and change management.
- Temporary productivity loss during startup and stabilization.
Compare acquisition models on the same timeline. Capital purchase, lease, and robots-as-a-service can allocate cost differently. Contract terms may also limit flexibility when volumes change. Model cash flow, termination rights, support obligations, and expansion pricing.
How should safety be evaluated?
Safety requires a site-specific risk assessment, not a feature checklist. Sensors and emergency stops do not make every application safe. Load stability, speed, stopping distance, visibility, intersections, and human behavior affect risk. Assign responsibility across the manufacturer, integrator, and warehouse operator.
The current standards landscape includes ISO 3691-4 for driverless industrial trucks and their systems. ANSI/A3 R15.08 addresses industrial mobile robots, system integration, and continued use. The 2026 R15.08 package now includes separate requirements for manufacturers, integrators, and users. Engage qualified safety professionals to determine which standards apply.
Design controls around the actual operating environment. Review pedestrian crossings, blind corners, docks, fire routes, manual lift trucks, and maintenance access. Define speed zones and restricted areas where appropriate. Reassess risk after material changes to routes, loads, software, or layout.
Training remains essential after engineering controls. Employees need rules for interacting with robots, clearing obstructions, responding to alarms, and reporting near misses. Maintenance teams need lockout and recovery procedures. Test emergency response before go-live.
What operating risks get missed?
Congestion is one of the most common overlooked risks. A robot may avoid a person safely but still block an aisle or starve a workstation. Multiple robots may compete for the same intersection, charger, or destination. Measure mission completion time under realistic traffic.
Downstream imbalance can erase upstream gains. Faster picking creates little value when packing, replenishment, consolidation, or shipping cannot keep pace. The operation may simply move its queue. Model the end-to-end process before approving the equipment.
Exception handling often receives too little design attention. Teams focus on the normal mission and improvise the recovery process. A stopped robot, missing tote, full destination, or bad scan can disrupt several orders. Document ownership, alerts, escalation, and manual fallback.
Vendor dependency can become another hidden constraint. Proprietary software, interfaces, chargers, and payloads may limit future choices. Support response and spare-part availability affect uptime. Evaluate the exit path before committing to the platform.
How should an AMR pilot be designed?
A pilot should test the business process, not merely prove that a robot can move. Select a representative workflow with measurable volume and manageable risk. Include realistic products, employees, systems, and exceptions. Define success before equipment arrives.
The pilot should measure:
- Completed missions and units moved per hour.
- Associate travel and direct labor hours.
- Queue time, blocked time, and mission cycle time.
- Robot availability, charging time, interventions, and downtime.
- Pick or transfer accuracy and inventory synchronization.
- Safety events, near misses, congestion, and employee feedback.
- Downstream throughput, cutoff performance, and exception volume.
Run the pilot long enough to move beyond demonstrations and novelty. Include more than one shift when staffing or operating conditions differ. Test peak-like bursts and degraded conditions. Compare results with the documented baseline.
Set expansion gates before the pilot begins. Expansion may require minimum throughput, uptime, accuracy, and intervention performance. It should also require acceptable employee adoption and safety results. Do not scale a pilot that needs constant vendor attention.
How should executives compare AMR vendors and integrators?
Executives should compare the proposed operating outcome before comparing robots. Give each provider the same data, constraints, scenarios, and acceptance requirements. Require providers to state assumptions and exclusions. Normalize total cost and performance across proposals.
Ask every provider to document:
- The exact workflow, load, routes, and operating conditions assumed.
- Required robot count for average, peak, and degraded conditions.
- WMS, WES, fleet, and equipment integration responsibilities.
- Throughput, mission time, uptime, and intervention assumptions.
- Safety responsibilities, risk-assessment scope, and documentation.
- Site preparation, network, charging, and facility requirements.
- Testing, acceptance, training, support, and escalation procedures.
- Warranty, software licensing, cybersecurity, and upgrade policies.
- Expansion pricing, interoperability, data access, and exit rights.
- References with comparable workflows, loads, and operating scale.
Separate manufacturer capability from integration capability. A strong robot can fail inside a weakly designed process. A skilled integrator should translate operational requirements into controls, software, equipment, and acceptance tests. Confirm who owns end-to-end performance.
Use demonstrations carefully. A scripted demo proves controlled functionality, not peak operational performance. Request evidence from comparable applications. Validate the evidence during reference calls and site visits.
What should the contract and acceptance plan require?
The contract should convert the proposed outcome into measurable obligations. Define scope, data interfaces, equipment, software, site work, and customer responsibilities. State performance assumptions and acceptance conditions. Resolve ambiguity before the purchase order.
Acceptance testing should reflect real operating conditions. Define test volume, duration, product mix, staffing, system interfaces, and permitted exclusions. Include recovery from common faults and connectivity loss. State the remedy when a requirement fails.
Support terms need the same precision. Define severity levels, response times, coverage hours, spare-parts expectations, and escalation. Clarify remote access, cybersecurity, updates, and version support. Include a transition plan if the relationship ends.
How should change management support the deployment?
Change management for AI and automation in warehousing should begin during design. Associates understand walking, waiting, congestion, and exceptions that reports may miss. Their input can improve workstation and route design. Early participation also reduces uncertainty about job changes.
Define future roles before go-live. Operators may shift from transport to picking, exception handling, or process control. Supervisors need new performance views and escalation procedures. Maintenance and IT teams need ownership boundaries.
Train by role and validate competency. Classroom instruction alone will not prepare teams for live exceptions. Use hands-on practice with realistic loads, alarms, blocked routes, and recovery steps. Plan refresher training after stabilization.
What is FCBCO’s recommended AMR decision process?
FCBCO’s warehouse automation consulting uses a problem-first, evidence-based decision process. The process separates operating diagnosis from equipment selection. It also creates measurable requirements before vendors influence the design. Follow these seven steps.
- Define the business problem. Identify the service, labor, capacity, safety, or cost constraint.
- Measure the current process. Quantify volume, travel, labor, queues, errors, and exceptions.
- Improve the process first. Correct avoidable layout, slotting, inventory, and workflow problems.
- Compare alternatives. Evaluate AMRs against process changes, conventional equipment, and other automation.
- Model the future operation. Size robots, workstations, charging, labor, and downstream capacity.
- Pilot against acceptance criteria. Test normal work, peak-like conditions, failures, and recovery.
- Scale only after validation. Expand when safety, economics, integration, and operating performance meet the gates.
This sequence protects the investment from equipment-driven decisions. It also gives vendors a clearer problem to solve. The result should be an operating design with technology inside it. It should not be a robot searching for an application.
Questions executives should answer before approving an AMR project
Executives should delay approval until the following questions have clear answers:
- What measured constraint will the AMR remove?
- Which tasks, trips, loads, and operating hours are in scope?
- What process improvements should occur before automation?
- What alternatives were evaluated on the same requirements?
- What data supports the fleet size and workstation design?
- How will the design perform at peak and during equipment downtime?
- Which system owns tasks, priorities, inventory updates, and exceptions?
- What facility, network, charging, and safety work is required?
- What costs exist beyond the robots and quoted software?
- Which labor hours can the operation actually avoid or redeploy?
- How will success be measured during pilot and acceptance testing?
- Who owns integration, safety, support, and end-to-end performance?
- What prevents vendor lock-in and protects access to operating data?
- What is the fallback process when the fleet or interface fails?
Frequently asked questions about warehouse AMRs
Do AMRs require a warehouse management system?
AMRs do not always require a WMS, but most scalable warehouse applications need a reliable task source. The WMS, WES, or another system may create and confirm movement work. Manual task entry can support simple pilots but may limit control and traceability. Define the long-term integration before scaling.
Can AMRs work safely around people?
AMRs can operate in shared spaces when the complete application controls risk appropriately. Safety depends on the robot, load, speed, routes, traffic, environment, and work rules. A compliant component does not replace a site-specific risk assessment. Validate the integrated application before production use.
How many AMRs does a warehouse need?
Fleet size depends on mission demand, travel distance, payload exchange, charging, congestion, and availability. A simple average can understate peak needs and overstate utilization. Model missions by time interval and test the design under peak-like conditions. Include spare capacity for downtime and variation.
How long does an AMR implementation take?
Implementation time depends on application complexity, integration, site work, testing, and change management. A limited transport pilot may move faster than an integrated picking system. Vendor lead time represents only one part of the schedule. Build the plan from requirements through stabilization.
Do AMRs eliminate warehouse jobs?
AMRs usually automate movement tasks rather than every activity within a role. The operation may reduce required labor hours, redeploy employees, or avoid future hiring. People still manage exceptions, maintenance, supervision, and variable work. Base the business case on achievable labor changes.
Are AMRs always cheaper than conveyors?
No technology is always cheaper. AMRs may require less fixed infrastructure and support phased growth. Conveyors may deliver lower unit cost on stable, high-volume routes. Compare lifecycle cost and operating performance for the specific flow.
What is the biggest AMR implementation mistake?
The biggest mistake is selecting equipment before defining the operating problem and requirements. This reverses the decision process and encourages optimistic assumptions. Diagnose the process, quantify the constraint, and compare alternatives first. Then invite vendors to solve a documented problem.
Make the operating decision before the equipment decision
AMRs can become valuable tools for reducing travel and creating flexible material flow. Their success depends on process design, data, integration, safety, and operating discipline. The strongest project may also conclude that another solution fits better. Make that determination before vendor selection.


SHARE